Projects
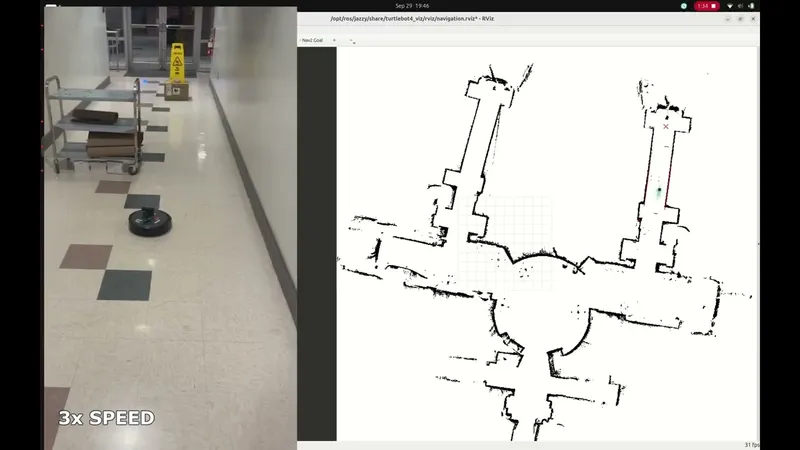
Cross-Embodiment Autonomous Navigation
Autonomous navigation demonstrated across different robot bodies, with a real robot driving a hallway using Nav2 alongside the map in RViz.
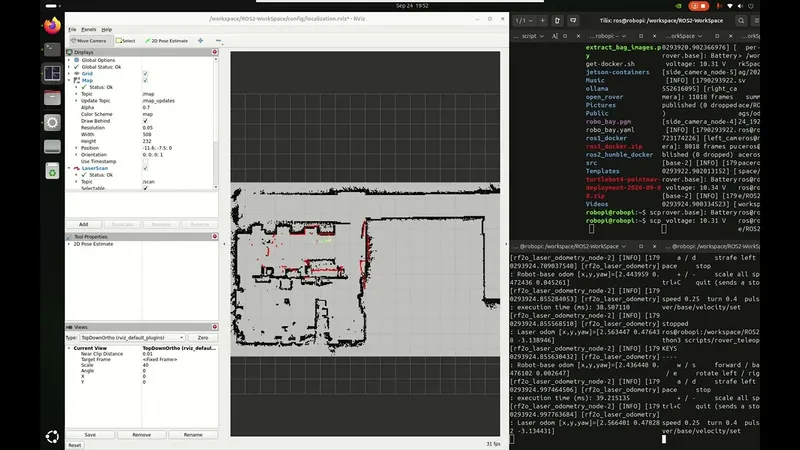
OpenRover EKF Sensor Fusion and AMCL
Sensor fusion with an extended Kalman filter and AMCL localization on an OpenRover, visualized live in RViz against a lidar map.
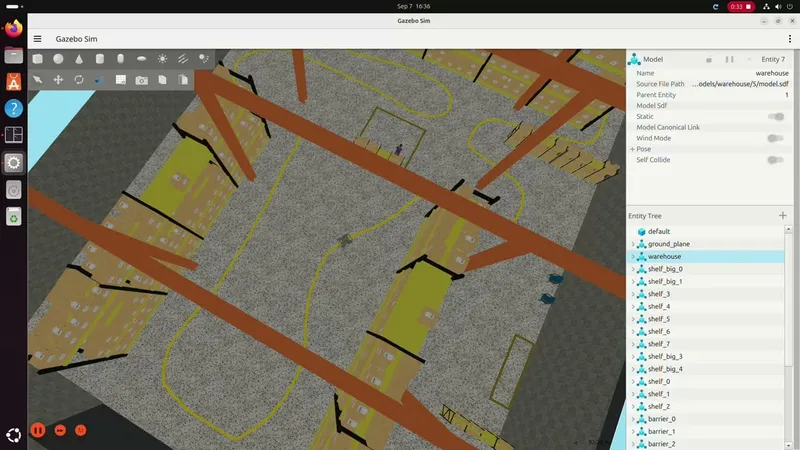
Line Following in Gazebo: Husky and Go1
Line-following controllers tested on two different robots in Gazebo: a Clearpath Husky AGV and a Unitree Go1 quadruped, each following a painted line through a warehouse world.
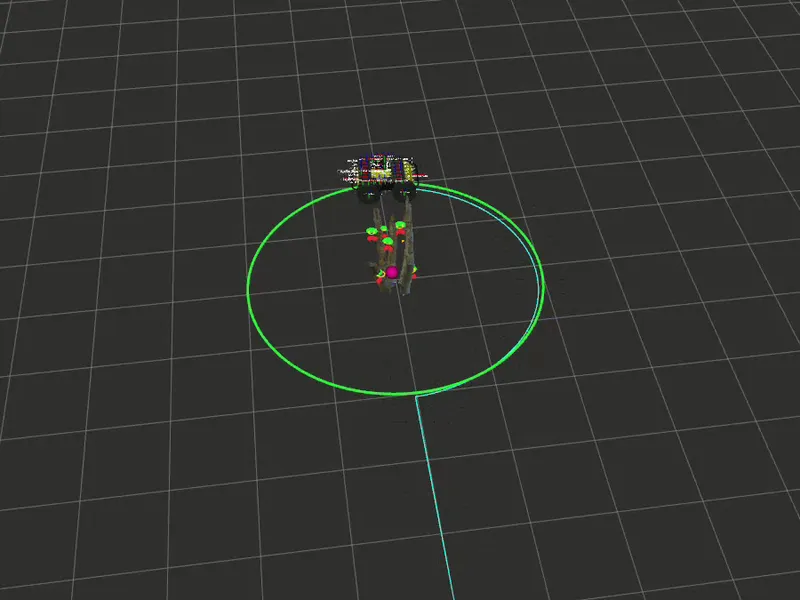
Lidar-Guided Orbit Around a Bamboo Culm
A simulated Clearpath Husky finds a bamboo culm bundle with 2D lidar and drives a closed-loop 2 m orbit around it, holding 6.5 mm RMS radial error against ground truth over a full lap.