OpenRover EKF Sensor Fusion and AMCL
Overview
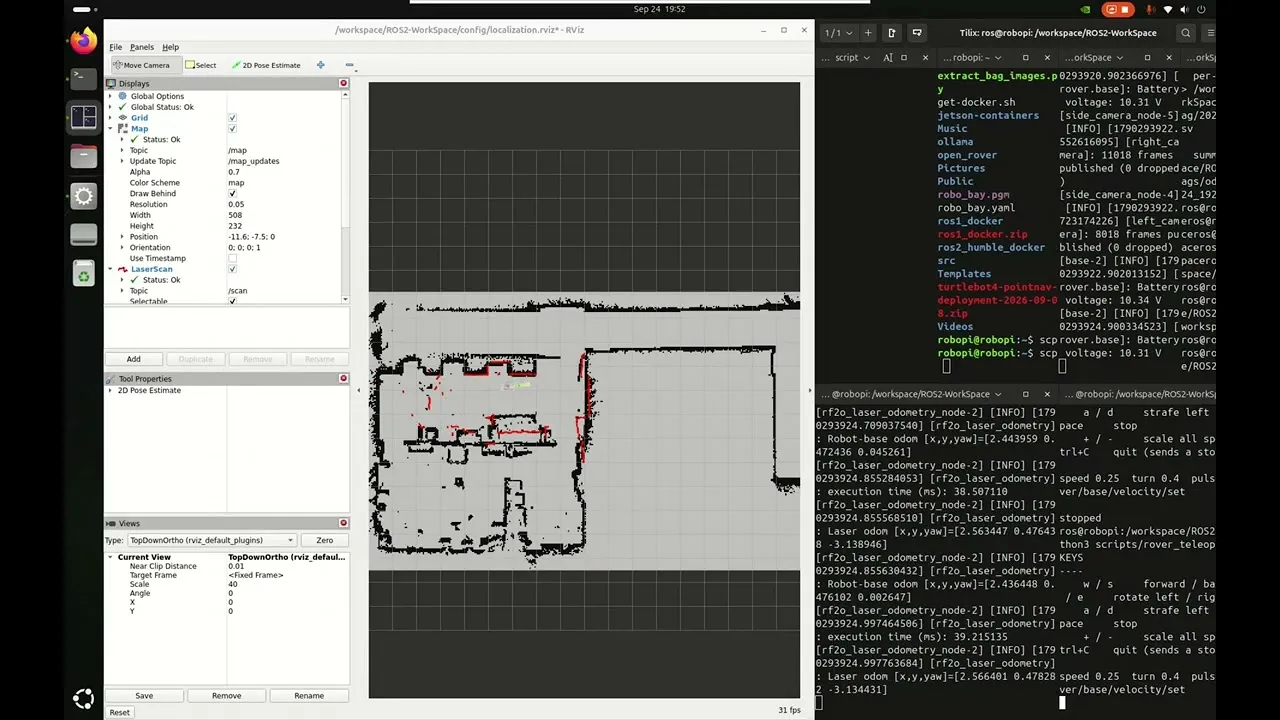
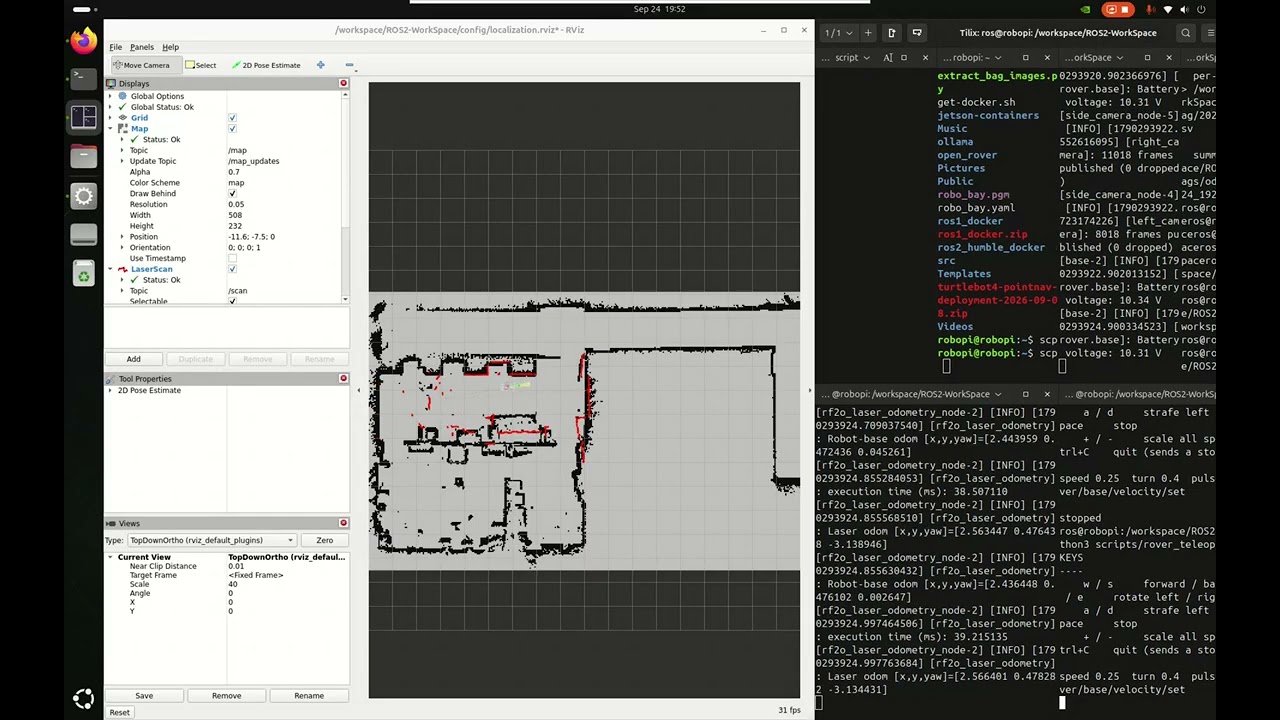
An OpenRover localizing itself with an extended Kalman filter for sensor fusion and AMCL against a prebuilt map. The video shows RViz with the live laser scan overlaid on the map, alongside the rover’s odometry and teleop terminals.